All mechanical engineering students must undertake a capstone project in their senior year. The capstone projects are part of the 2-quarter Mechanical Engineering Design I & II course that is offered in Fall-Winter or in Winter-Spring. Students are guided by lecture material, mentors, and TAs while they work on their projects in teams of 3-6. The Department is always interested in collaborating with industry and/or community mentors who would like to have students work on an open-ended design project. An introduction to the mechanical engineering capstone projects program is available here. Please reach out to Professors Mark Walter (m.walter@uci.edu) or David Copp (dcopp@uci.edu) if you have any questions. 


SAE Micro Class Plane
Summary

Spanning several years, Aero Design @ UCI (formally UCI Cargo Plane) is a well-renowned project at the University of California, Irvine. This project provides a great opportunity for undergraduate students to learn the fundamentals of aircraft design, as it brings together the foundations of aerospace engineering and combines them with hands-on manufacturing experience. These skills will aid these members in future endeavors where they may design planes that could potentially carry more precious cargo. Given the formidable challenge by SAE, teams are expected to bring together unique perspectives in creating a one-of-a-kind RC aircraft, capable of meeting all constraints. All participating teams are expected to go through the entire design process, create a thorough design report, and present the team’s design to a panel of industry engineers.

Our goal for our project is to design and build a small-scale aircraft that contains a liquid payload with minimal...

DialiTEAM

Our project’s goal is to read the hematocrit value in blood using optics, otherwise known as a hematocrit sensor. This device is made to be integrated onto our sponsor’s (Diality) machine and will allow them to read a patient's blood volume rate. Critical design features of the device include: the accuracy of sensing hematocrit; the handling of hazardous material; and the usability of the machine by physicians and at-home caregivers. Stakeholders, including Dialysis Clinic, Technicians, Patients, Caregivers, Dialysis Field Service Technicians, and physicians/Nephrologists.

Toy Cannon: B.A.L.L.


This project aims to design a cannon system that is capable to detecting, tracking, and hitting moving targets within a 360-degree area at a distance from 5 - 15 feet. With the exception of loading cannon balls, the system should work independently even without any user knowledge. By utilizing ultrasonic sensors and computer vision with OpenCV we accomplished autonomy, creating a system that is trained to hit RC Cars. Upon initial detection, our cannon automatically corrects pitch and yaw values to launch cannonballs at the target's predicted path position.

SmartSweat - Wearable Sweat Chemical Analyte Patch

SmartSweat is a wearable patch that non-invasively and continuously measures lactate and sodium content in sweat. The device functions through a screen-printed electrochemical sensor integrated with microfluidic pads that channel sweat to the electrodes. A custom physical housing and adjustable band provides comfort and ensures the patch remains in contact with the skin, even during exercise/activity. The embedded bluetooth module transmits the data wirelessly to a mobile device, allowing users to view live analysis of health activity. The device enables users to monitor performance, prevent dehydration, and make informed decisions during daily activities. By combining low-cost materials and compact materials, SmartSweat demonstrates a unique access for dual monitoring of sodium and lactate levels. Targeted towards athletes and health-conscious consumers, SmartSweat can provide valuable input on hydration and metabolic performance. 

UAV Forge (duplicate)

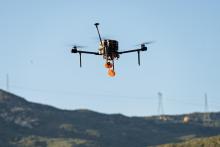
UAV Forge constitutes a multidisciplinary engineering design team with a specific focus on the comprehensive development cycle of autonomous aerial vehicles, encompassing design, manufacturing, programming, and rigorous testing. The paramount objective of this design endeavor is to adhere to the stipulated constraints, thereby enabling active participation in the SUAS 2025-2026 competition season.

UAV FORGE

UAV Forge Logo

Background

UAV Forge constitutes a multidisciplinary engineering design team with a specific focus on the comprehensive development cycle of autonomous aerial vehicles, encompassing design, manufacturing, programming, and rigorous testing. The paramount objective of this design endeavor is to adhere to the stipulated constraints, thereby enabling active participation in the SUAS 2025-2026 competition season.

The SUAS competition mandates that the UAV system possesses autonomous flight capabilities, proficient object avoidance capabilities pertaining to both stationary and dynamic entities, and adeptness in object detection, localization, and classification. Furthermore, the system is required to execute an airdrop delivery mechanism, ensuring the precise delivery of a payload object to a designated GPS location without incurring any damage.

Goal and Objectives 

While the immediate focus of this year’s team centers on achieving commendable performance within the competitive arena, the overarching goal is to provide undergraduate participants with a...

Fuel Blending Systems Control and Demonstration

The Fuel Blending System Control and Demonstration project focuses on modernizing and integrating advanced control and data acquisition technologies for the UCI Combustion Lab’s fuel mixing system. This system supports testing on multiple end-use devices, including gas turbines, fuel cells, and other combustion systems, which are being adapted for operation on low-carbon fuels such as hydrogen and biogas. The project involves reviewing existing system components, developing a comprehensive bill of materials (BOM) for upgraded hardware and software (e.g., LabView, Python, or MATLAB-based control), and ensuring full system compatibility. Once the updated components are procured, the team will integrate and demonstrate the system’s performance on one or more devices. The project aims to enhance flexibility, reliability, and data quality in fuel blending operations, supporting ongoing research in hydrogen and low-carbon fuel applications.

Narcotic Network

We are narcotic network as the word narcotic means to relieve great pain and that’s our goal, we want to create a network of pain relief through our medicine delivery advice, furthermore we want to get rid of the negative stigma associated with narcotics and create something that improves society instead.

  • Our project goal is to create a network of medication delivery centered around a pharmacy using autonomous drones

  • There are many problems with the procurement of medication, it takes too long just to speak with staff, medication may not be ready by the time you show up.

  • This is for individuals that either cannot physically be in person to pick up medication at the pharmacy, those that cannot be at the pharmacy due to a time constraint or impatience, and for convenience.

Flapping Wing Micro-Air Vehicle

About Us

Humans have achieved flight, yet birds and insects still surpass man-made aircraft in agility and control. The Flapping Wing Micro Air Vehicle (FWMAV) team seeks to uncover how nature achieves such mastery. By studying creatures like hummingbirds and dragonflies, engineers analyze the unsteady aerodynamics and nonlinear mechanisms that enable efficient, stable flight.

FWMAV’s small, agile, and hovering capabilities have applications in law enforcement, defense, and scientific research. The project investigates the physics behind flapping-wing flight to design innovative aerial systems.


Subteams

  • Alpha Quadflapper: Optimizing a Quadflapper that is robust enough to perform maneuvers that are critical to showcasing the flapper.

  • Gamma Quadflapper: Creating a “framework” that allows for the rapid prototyping of robust Gamma Quadflapper iterations.

  • Novel 1 - X-Wing: Creating a Variable-Frame-Angle Quadflapper drone that can take advantage of theoretical efficiency benefits.

  • Novel 2 - Single Wing: Optimization of a true Micro-Air-Vehicle (<50

  • ...

FUSION Engineering Project: Remote-Controlled Precision Cargo Drone

Background

The FUSION Engineering Project, as an integral component of FUSION, offers extensive learning opportunities that extend beyond the confines of traditional classroom education. This project fosters professional growth, catering to students at various stages of their educational journey—be it novices learning software applications like SolidWorks or TinkerCAD, or more seasoned engineering students seeking to grow their leadership capabilities through team management and mentorship. The FUSION Engineering Project (FEP) represents an intermediate-level project designed to impart crucial engineering skills to students at various stages of their academic journey.

Goal and Objectives

This year's project structure includes both mechanical and hardware components. The mechanical team is responsible for the design and prototyping of the frame and pick-up mechanism, while the hardware team is responsible for the wiring of the drone and selecting correct motors for the drone. The objective of each team is to create a drone capable of precise movement...

FLAM@UCI

The goal of the FLAM@UCI project team is to collaboratively construct a museum-quality restoration of a 1918 Curtiss JN-4D "Jenny," an iconic World War I-era biplane used primarily for training U.S. military pilots. The restored aircraft will be non-flying but must accurately represent the original aircraft in dimensions, appearance, and structure, down to the materials, methods, and finishes wherever possible. The Curtiss JN-4D will be a featured piece at the Flying Leatherneck Aviation Museum, currently being built in Irvine Great Park. This isn’t just a build project — it’s a historical reconstruction effort requiring technical precision, planning, and teamwork. 

This collaboration engages UCI undergraduate students in an immersive, hands-on learning experience by partnering with the expert staff/volunteers of the Flying Leatherneck Aviation Museum (FLAM) and the Experimental Aircraft Association (EAA). Through the joint effort of building a historically accurate replica of the 1918 Curtiss JN-4D “Jenny” with...

UCI Solar Airplane (2024-2025)

Our purpose:

The purpose of the UCI Solar Airplane project is to prove the viability of solar energy as a substitute for nonrenewable fuel and to provide aid in search and rescue missions during natural disasters where drones and other methods would not be effective. Climate change has progressed at an alarming rate, especially in recent years, making it evident that a drastic change in energy use is necessary. Even so, today’s most commonly used energy source globally is still fossil fuels. While the renewable energy market continues to expand, it is vital to concentrate efforts into promoting applications of clean energy.

The Solar Airplane team works to prove that solar energy is a viable alternative to fossil fuels in aviation in hopes that it will spur an increase in solar energy applications for other energy needs as well. Our project will conducts extensive research into solar panels and aviation to...

Design-Build-Vertical Flight

The DBVF (Design-Build-Vertical Flight) competition is an eVTOL (electric-powered remote-control vertical take-off and landing) vehicle competition where university students have the opportunity to gain hands-on experience and familiarize themselves with eVTOL and AAM (advanced air mobility). 

Student teams annually design, build, and test an eVTOL aircraft to meet specific objectives and attend a flyoff in Maryland, where they are scored on their ability to meet those objectives. 

UCI’s DBVF team AeroZot currently consists of members who are split into subteams to develop the airframe, hardware, software, and the financing of the eVTOL.

HyperXite 10

Summary

HyperXite is a multidisciplinary undergraduate student team at UC Irvine dedicated to creating sustainable transportation technology through innovative research and development. Our project aims to revolutionize high-speed travel by designing and building a small-scale, self-propelled train pod that validates system models, incorporates important sustainable technologies, and proves the feasibility of Hyperloop and magnetic levitation concepts.

Background 

The Hyperloop, introduced in 2013, represents a revolutionary mode of transportation, utilizing magnetically levitated pods propelled by electromagnetic forces within a near-vacuum tube. This design minimizes air resistance and eliminates friction, enabling speeds of up to 760 mph. HyperXite, a team dedicated to advancing Hyperloop technology, focuses on developing a small-scale monorail version of the pod. Since its establishment nine years ago, the team has worked to align its research with full-scale Hyperloop applications, emphasizing friction reduction through electromagnetic technologies and optimizing mechanical and electrical systems for efficiency.

HyperXite has gradually transitioned from...

FUSION Engineering Project: Remote-Controlled Precision Cargo Drone

FUSION Engineering Project Team Logos

The FUSION Engineering Project is a student-run engineering project that is managed by the club organization FUSION (Filipinx Undergraduate Scientists-Engineers In an Organized Network). The year-long project for the 2024-2025 academic year is a Remote-Controlled Precision Cargo Drone. This drone will have the capability to pick up a 2x2x2 in. wooden block and precisely deposit it at a landing zone. The drone will be controlled via remote control, and each team will implement their own creative designs including cameras, sensors, and other components to achieve this goal. At the end of the year, each team will use their drones to complete challenges in a competition. Each team will also be given the opportunity to present their work at our yearly conference FUSIONCon.

Anteater Formula Racing - Drag Reduction System

Background 

Anteater Formula Racing is a FSAE team at UCI that is dedicated to designing, building, and competing with an open-wheel, internal-combustion race car inspired by Formula 1 and IndyCar racing. The DRS project team is working closely with the Aerodynamics, Human Interface, and Electronics subteams within Anteater Formula Racing to design, test, and implement a drag reduction system on the existing rear wing of the vehicle, in order to improve race times and performance. 

Goal and Objectives 

The objective of Team DRS is to integrate a drag reduction system on the rear wing of the car in order to improve race times. By changing the position of the top two airfoils, the drag coefficient will be modified to adapt to the racing environment. The actuation of the system will have an automatic component, controlled by vehicle speed, and can also be activated manually by the driver. Additionally, the system...

Innovative Cold Plate

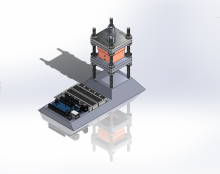
The cold plate heating apparatus, cold plate clamp, data collection and electronic control assembled

Background

The rapid growing field of AI and high-performance computing has led to small-form factor chips (CPUs/TPUs) with exceedingly high heat fluxes. Traditional air cooling struggles to dissipate these thermal loads efficiently. The research from our team at UC Irvine proposes an innovative liquid-vapor phase change cooling plate to address the need for high-performance cold plates that integrate seamlessly with new generation server hardware.


Goal and Objectives

The team seeks to accomplish the following:

Q1 2025 (first half of winter quarter): Market research on industry chip cooling tech and academic literature on heat transfer fundamentals

Q2 2025 (second half of winter quarter): Finalize a design matrix via trade studies, providing complete design proposals for internal/external components, testing/data collection, and ANSYS fluid simulations

Q3 2025 (first half spring quarter): Validate manufacturing process and achieve target metrics in prototype testing

Q4 2025 (second half spring quarter): Revise design, scale for certain server motherboards and...

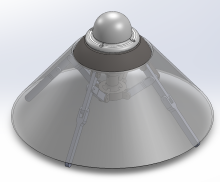
Breathe Ez

Our project focuses on developing a breathing device that delivers controlled airflow while promoting a positive user experience. Designed with durability and scalability in mind, this device ensures long-term reliability and cost-effective manufacturing, making it both practical and accessible.

By utilizing high-quality materials and an ergonomic design, we aim to create a seamless, user-friendly solution that integrates effortlessly into daily life. The device will withstand regular use without compromising performance, maintaining both safety and efficiency. Additionally, the design will be optimized for mass production, ensuring affordability without sacrificing quality.

Careful material selection and engineering will enhance usability, comfort, and longevity, making the device intuitive and maintenance-free. Our goal is to develop a reliable and effective solution that meets the highest standards of functionality while providing a smooth and controlled inhalation experience.

Background: 

Access to safe and effective inhalation devices is a growing concern, as many existing products on the market...

JellyfishBot

The UCI JellyfishBot team aims to develop a bioinspired underwater robot that mimics jellyfish movement for marine exploration within two academic quarters (Winter and Spring 2025). As the first project of its kind at UCI, the design features three subsystems: a linkage-based propulsion system, chassis, and electronic/control component. 

Coastal Currents

Coastal Currents Logo

The goal of our project is to design and develop a device that can be used by coastal residences to generate electricity utilizing the waves in the ocean. Approximately 71% of the earth's surface is water, making this a very promising and bountiful resource. Large scale wave energy generators are already in commission but are unfeasible to use for individual households. To accommodate small-scale power generation needs, Coastal Currents is developing a compact wave-energy generator that is intended for residential use on the coastline to provide power directly to homes by utilizing the energy and geometry of the ocean’s waves.

HeliCraft

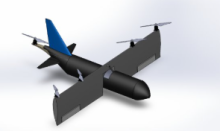
This project focuses on the design of a Tiltwing VTOL drone that combines fixed-wing efficiency with vertical takeoff and landing flexibility. The rotating wings enable smooth transitions between hover and cruise, improving maneuverability. The goal is stable flight, reliable performance, and payload capacity. The final design integrates aerodynamics and control systems into a compact, high-performance UAV.

Formula SAE Electric - Brakes

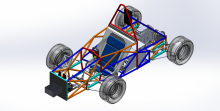
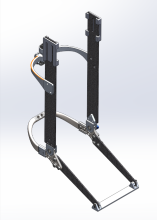
The brakes sub team aims to design a reliable and well-organized braking system for Anteater Electric Racing’s KiloZott, ensuring optimal performance, safety, and efficiency. To achieve this, the system will integrate regenerative braking to enhance energy recovery and feature configurable pedals for improved adaptability and driver preference. Whenever feasible, existing components will be incorporated to optimize cost and compatibility. A comprehensive CAD model will be developed prior to prototyping and assembly to ensure precision and minimize design iterations. This approach will result in an effective braking system that seamlessly integrates into the vehicle’s overall functionality, supporting the team's objectives in electric racing performance.

EV Driver Cockpit Subsystem Prototype

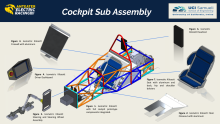
The Driver Cockpit Subsystem focuses on improving driver comfort, control, and safety in Kilozott, Anteater Electric Racing's newest car for the 2024-2025 season. The project includes the design, CAD modeling, and manufacturing of the seat, headrest, firewall, and steering system.

Testing revealed wrist strain from steering angles, inadequate lateral seat support, and inconsistent pedal resistance. To address these, the team is refining seat bolsters, steering ergonomics, and pedal feedback while ensuring seamless chassis integration.

Key improvements include a redesigned seat with extended bolsters, an optimized steering position, and an adjusted firewall for better helmet clearance. The team will finalize the prototype based on driver feedback and conduct static and dynamic testing before competition.

Autonomous Exploration

Our autonomous exploration rover is designed to navigate unknown environments with precision and efficiency. Equipped with a LiDAR scanner and IMU sensors, the rover creates detailed 3D maps and efficiently plans optimal paths to its destination. Using the RRT* (Rapidly-exploring Random Tree Star) algorithm, it navigates complex terrains while avoiding obstacles in real-time.

The rover’s advanced motion control system ensures smooth and accurate movement. Integrated with ROS (Robot Operating System) and built on the Waveshare JetRacer platform, the system delivers excellent performance and adaptability.

Designed for versatility, this autonomous rover has military applications with a powerful solution for exploring challenging environments safely and efficiently.

Ankle Exoskeleton

Our project aims to develop a lightweight and modular ankle exoskeleton to assist stroke patients in rehabilitation. Existing solutions are often bulky, difficult to use, and not adaptable to various shoe sizes. Our design integrates a quick-release mechanism to ensure easy, equipping and donning off, improving user experience for patients and physical therapists. The exoskeleton will provide supportive yet lightweight force assistance, enhancing mobility without adding excessive strain. The final prototype will be tested to validate comfort, force application, and user adaptability.


Goal and Objectives

  1. Develop a compact, lightweight, and ergonomic exoskeleton
  2. Integrate a quick-release mechanism to improve ease of use
  3. Optimize force capabilities and manufacturability
  4. Accommodate foot sizes from 7 to 13
  5. Ensure the total weight does not exceed 300g
  6. Finalize prototype testing and documentation for future manufacturing

Sponsor/Advisor


Firefly

Background

This project focuses on the development of an autonomous drone system designed to survey an area, detect wildfires or fire outbreaks, and intervene with fire retardant to mitigate the spread of flames. The drone is equipped with sensors and cameras, to identify fire hotspots in real-time. Using color-filtering algorithms in addition to sensors, the system can accurately distinguish between fire and non-fire events, ensuring high precision in detection.

Once a fire is detected, the drone autonomously navigates to the location and deploys a fire retardant payload, such as dry agents or water-based solutions, to suppress the flames. The system is integrated with GPS and mapping technologies to optimize flight paths and ensure efficient coverage of the survey area. Additionally, the drone can transmit real-time data and alert ground station, enabling rapid response.

Goals and Objectives

Our main goal is to design an autonomous drone system that is capable of...

Resilient Mobile Space Launch System

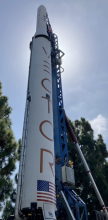
We are designing a mobile rocket launch system that can be transported across all U.S. highways, complying with Department of Transportation regulations in every state. The system consists of two main subsystems: the Transporter, Erector, Launcher (TEL) and the launch vehicle (rocket). The TEL includes a hydraulic erector system capable of lifting the rocket to a full 90 degrees while providing full support with a strong back. The launch vehicle can deliver a minimum 200 lb payload to a 500 km polar orbit (270 Nmi/Polar) and features a reusable first stage designed to land on any surface after launch. The rocket will use existing models of rocket engines and will be powered by liquid propellants. The launch platform will secure the rocket during the initial launch at 100% thrust utilizing a ground drilling mechanism. The entire system can be fully set up within 8 hours of arriving at the launch site. This mobile launch system can be deployed anywhere across America, which eliminates the limitations of being confined to the two current launch sites in Vandenberg, California, and Kodiak, Alaska.


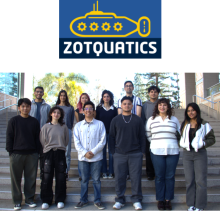
ZotQuatics

ZotQuatics Logo and Goup Photo

About Us
The UC Irvine ZotQuatics team works towards designing and manufacturing an Autonomous Underwater Vehicle (AUV) to compete in the annual RoboSub Competition hosted by RoboNation. Teams from around the world come together to test their AUVs through a series of underwater objectives and present their work through technical documentation. Our AUV will also have applications in environmental remediation.

Our ultimate goal for 2024-25 is to establish ZotQuatics as a permanent pillar of the UCI Engineering community. We will do this by designing and fabricating Mark I of the ZotQuatics AUV as a platform for future teams to build off on and evolve. The Mark I shall adhere to RoboSub regulations regarding functionality, performance, constraints, and design attributes we identify to meet these requirements.

BoardBox — Anti-Theft Device for Personal Electric Vehicles

Summary:

Our project focuses on enhancing the security and storage of personal electric vehicles (PEVs) on campus. With rising theft rates of electric scooters and skateboards, as evidenced by UCIPD reports, students often bring their PEVs into lecture halls, violating fire codes and causing unnecessary congestion. Existing campus infrastructure lacks a secure and convenient solution, creating frustration for students and faculty alike.

To address this issue, we propose a secure locker system called BoardBox that allows students to temporarily store their PEVs using a mobile application. These lockers will feature a sophisticated locking mechanism—a multi-surfaced, linear-sliding, servo-powered system—along with integrated charging through solar panels and mobile phone compatibility. By providing a safe storage option, our system could encourage greater use of PEVs, alleviating campus parking challenges and promoting sustainable transportation. Additionally, this project presents an opportunity for the university to enhance campus amenities while exploring potential revenue streams.

Anteater Dynamics

Anteater Dynamics is a mechanical engineering senior design project team working with the robotics company ROBOTIS to design a low-cost 7-degree-of-freedom robotic arm targeted for personal robotics enthusiasts, capable of collecting data to be used in machine learning. The final product should be under $1000 to fulfill ROBOTIS’ vision of easily accessible robot technology.

Pages