All mechanical engineering students must undertake a capstone project in their senior year. The capstone projects are part of the 2-quarter Mechanical Engineering Design I & II course that is offered in Fall-Winter or in Winter-Spring. Students are guided by lecture material, mentors, and TAs while they work on their projects in teams of 3-6. The Department is always interested in collaborating with industry and/or community mentors who would like to have students work on an open-ended design project. An introduction to the mechanical engineering capstone projects program is available here. Please reach out to Professors Mark Walter (m.walter@uci.edu) or David Copp (dcopp@uci.edu) if you have any questions. 


Hydrovision

Renewable Hydrogen is a possible alternative fuel to natural gas that can be used in gas turbines without producing greenhouse gas emissions. However, all combustion processes produce NOx, which is a harmful air pollutant and isn’t very well studied for Hydrogen. Our sponsor seeks to better understand hydrogen combustion by examining the interaction between hydrogen flames, but lacks the equipment to fully study every region in the flame. Thus, we are tasked to design a mechanical device that moves a camera around the flames to capture the reaction, protects the device from the high temperature of the flames, and processes those images to create a 3D heat release map of the high temperature regions. This way, the researchers can pinpoint where the regions of NOx will occur based on these images and figure out ways to reduce the regions of high NOx production. 
Bike Frame Project

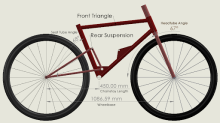
Over the winter and spring quarters, our project focuses on designing and manufacturing an affordable, DIY-friendly full suspension mountain bike for garage-level construction. 

We've finalized decisions on suspension and frame design, emphasizing manufacturability. Currently, we're refining designs for compatibility and performance, initiating proof of concept trials, and developing welding skills. Future steps include completing a comprehensive CAD model, sourcing components, fabricating a welding jig, welding the frame, assembling components, and showcasing finalized design. This project fosters collaborative innovation and empowers makers to shape the future of mountain biking technology

Inertial Compensation Unit - Conservation of Momentum Gimbal

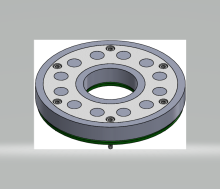
In order for satellites in orbit to maintain its heading to Earth, they utilize gimbals. Gimbals stabilize the payload which allow it to consistently point in the same direction even in motion. ICU is a MAE 151A/B project team in which we are developing a gimbal and counter gimbal mechanism to enable gimbal motion on small spacecraft without affecting attitude. The gimbal will be placed in low earth orbit in a 1U box with a high resolution camera to capture visual data of Earth. We are sponsored by Aaron Freeman and David Reeves of General Atomics who provide us industry knowledge and access to professional hardware.

Electro Permanent Magnet

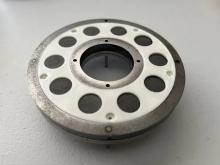
The Army Research Lab (ARL) has been working on wireless charging methods for drones and needs a way to easily attach and detach their drones from the charging point without taking too much power and space on the drone. Electropermanent magnets can be turned on and off but do not require constant power in the on stage which would be too strenuous on the drone. The ARL tasked UCI with developing a way to magnetically connect the drone to the charge surface quickly and have found EPMs to be the most viable option for this. Working with Professor Camilo Velez, we designed and fabricated a design of electro-permanent magnets (EPMs) within a metal casing that will allow for quick attachments and releases from the charge points. This prototype can produce a 60N normal holding force. 

Glide&Slide - Bottle Lift and Transfer Project - Team17B

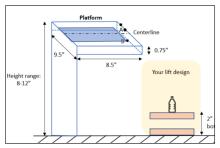
This is an automotive bottle lifting project. The bottle lift device needs to be compact, free-standing, and battery-operated. It may not extend underneath the landing platform and must allow for the bottle to start no greater than 2" from the ground. The lift must maintain the bottle's upright position throughout the journey and landing on the platform. Once the water bottle is placed onto the landing platform within the landing box, the lift must return to its original position and be ready to repeat the motion. Our design aims to be cheap, efficient, and effective while providing the same features as traditional assembly line devices. 


Bottle Lift and Transfer - Team 17A

Main Purpose: Finding an autonomous way of material transportation to improve a menial, repeatable task to improve efficiency in a manufacturing/packaging process


For this project, our main objective is to make a bottle lift and transfer mechanism that will transfer a 16oz water bottle from the ground onto a platform that is 8”-12” off the ground. The platform is a rectangular table of 8.5” x 9.5” with a thickness of 0.75”. The design is meant to be placed on the platform and retracts down again so that it can receive another bottle. To accomplish this, the mechanism would need to be able to move vertically to the platform height, but also transfer the bottle horizontally to make space for another bottle.

Planar Laser Induced Fluorescence (PLIF) System for the Study of High-Speed Reacting Flows

Combustion Crew Team Logo

The Combustion Crew, Team 14 with MAE 151B, is working to develop a Planar Laser-Induced Fluorescence system for their sponsor, Dr. Xian Shi at the X Energy Laboratory at the University of California, Irvine. Building on Dr. Shi's existing high-speed reacting flow experimental setup, the team research and design a compatible PLIF system given the complexities of studying detonation phenomena. The system, designed to target the hydroxyl (OH) radical, will serve as a combustion diagnostics tool alongside an existing Schlieren imaging system.

Wearable Gait Analysis Device

Team Stride Insight

The goal of this project is to develop an easy-to use, wearable, stand-alone device for gait assessment that can be sent home with patients and used continuously for at least 1 hour prior to recharging. The system needs to have an insole that measures user ground reaction forces and a soft interface to be worn around the ankle and calf to measure ankle angle and activity of at least two muscles: the tibialis anterior and the soleus or one of the gastrocnemius (calf) muscles. Processed data must be available to download after use that can be understood and analyzed by the wearer’s physician. The following pages will serve as a record of the work accomplished week-by-week including meeting notes, results from testing, and team discussions.

Electro Permanent Magnet

Background

The Army Research Lab (ARL) has been working on wireless charging methods for drones and needs a way to easily attach and detach their drones from the charging point without taking too much power and space on the drone. Electropermanent magnets can be turned on and off but do not require constant power in the on stage which would be too strenuous on the drone. The ARL tasked UCI with developing a way to magnetically connect the drone to the charge surface quickly and have found EPMs to be the most viable option for this. Working with Professor Camilo Velez, we designed and fabricated a design of electro-permanent magnets (EPMs) within a metal casing that will allow for quick attachments and releases from the charge points. This prototype can produce a 60N normal holding force. 

Goals and Objectives

Tasked with creating an EPM-powered magnetic attachment system that can accommodate...

Better Than Crutches!

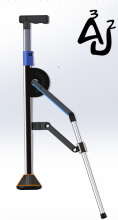
The Better than Crutch is project 16 of Winter 2024 MAE151A/B Mechanical Engineering design projects. In this innovative project, we aim to revolutionize mobility assistance by developing an automatic crutch that adjusts its height according to the user's needs. This state-of-the-art crutch provides unparalleled support and ease for individuals facing mobility challenges, especially when navigating complex terrains such as stairs, slopes, and uneven surfaces. This crutch is engineered for ergonomic comfort and user-friendly operation, reducing physical strain and enhancing the user's confidence and independence. Our project represents a significant leap in assistive technology, promising to substantially improve the quality of life for crutch users by offering a safer, more adaptable, and user-centric mobility solution.

Long Range Drone

The Long Range Drone is project 12 of the Fall 2023 MAE 151A/B Mechanical Engineering design projects. In this project, the team is expected to design a fixed-wing aircraft-like drone that is capable of maximizing flight distance and/or flight duration given a limited battery capacity with the current technology. In addition to designing a drone, the team is expected to develop a launcher that is capable of providing an initial boost to help the drone reach an optimal initial height using an elastic band releasing system. Once launched, the drone will transition to a gliding phase, minimizing the usage of battery while sustaining leveled flight.

Solar Airplane

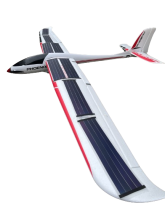
Mission Statement: Team 11B, Solar Airplane, seeks to create an RC solar airplane powered entirely from solar panels and battery power mounted on the aircraft for the purpose of demonstrating the efficacy of solar panels on extending flight duration.


Equitable Design Solutions

Equitable Design Solutions

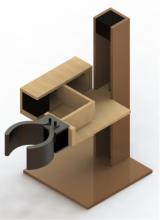
In an effort to increase accessibility in the classroom, we were tasked with redesigning the tablet arm desktops in UCI’s lecture halls. These desks, currently small and non-adjustable, lack consideration for left-handed individuals and students of various sizes. Our redesign features an armrest with three levels, allowing 3.5” of height adjustment and 4” of  depth adjustment. This flexibility, along with a fold-out desktop that provides 50% more surface area than the current design, should improve the classroom experience  for students of all proportions and handedness, allowing them to focus completely on learning.

2024 Winter Bottle Lift and Transfer Project -- Team 17C

Summary

For this project, we need to design a device that develops a bottle lift and transfer system capable of automatically placing a bottle onto a platform ( the blue area in the image) at a user-specified height, ranging between 8 and 12 inches. This device aims to streamline the process by enabling the device to return to its initial position after each cycle, ready to accommodate another bottle. The primary goal is to enhance the efficiency and safety of bottle lift and transfer procedures. The device should be free-standing, low-cost, easy to manufacture, and meet all the requirements of the sponsor and advisor.


Background 

Shorbagy Mohamed’s research as a PhD student at UCI is on dynamics and controls. As our sponsor, his dream design solution is that the product can lift and transfer the bottle to the other platform and is placed exactly at the center of the blue...

F1 - DragMaestros

The F-1 DragMaestros project group is working in conjunction with the Anteater Formula Racing Team to design, test, and integrate a drag reduction system on the rear wing of the vehicle to improve race times and overall performance. Through a detailed design process and project management, the team will determine the best method for changing the position of the rear wing airfoils to reduce the drag coefficient while balancing the lift coefficient. Actuation of the drag reduction system (DRS) will be controlled by the driver. This two-quarter project will develop a working 3-D printed scaled prototype by the end of the Winter Quarter of 2024 and plans to integrate a full-size manufactured system by the end of the Spring Quarter of 2024. 

Aspiration Ureteroscope: a medical surgical instrument for removal of kidney stones

A ureteroscope is a thin, flexible tube inserted into the ureter to access and remove kidney stones. At the moment, the surgical procedure for ureteroscopy is one that is laborious and does not remove enough kidney stones leading to repeat procedures for patients. We are remaking a ureteroscope with a larger diameter of 4.667mm with the goal of maximizing the aspiration channel, the channel where the kidney stones are suctioned out from, to achieve more stone removal. Our next goals will be to also have a non-clogging device, minimize all possible components to maximize aspiration channel even further and redesign the tip to allow the laser to access all stones more easily. 

FUSION Engineering Project: Mobile Gesture-Controlled Robotic Arm

FUSION Engineering Project Logos

The FUSION Engineering Project is a student-run engineering project that is managed by the club organization FUSION (Filipino Undergraduate Scientists-Engineers In an Organized Network). The year long project for the '23-24 school year is a Mobile Gesture-Controlled Robotic Arm. This mobile robot will have an attached arm that has the capability of grabbing, storing, and placing objects, as well as allowing for lateral movement. Both the robot’s movement and function of the arm are to be controlled wirelessly through hand gestures.There are 5 separate teams that are working to engineer their own individual robot that will be judged at a yearly conference hosted by FUSION (FUSIONCon). 

UAV FORGE

UAV Forge constitutes a multidisciplinary engineering design team with a specific focus on the comprehensive development cycle of autonomous aerial vehicles, encompassing design, manufacturing, programming, and rigorous testing. The paramount objective of this design endeavor is to adhere to the stipulated constraints, thereby enabling active participation in the SUAS 2024-2025 competition season.

The SUAS competition mandates that the UAV system possesses autonomous flight capabilities, proficient object avoidance capabilities pertaining to both stationary and dynamic entities, and adeptness in object detection, localization, and classification. Furthermore, the system is required to execute an airdrop delivery mechanism, ensuring the precise delivery of a payload object to a designated GPS location without incurring any damage.

While the immediate focus of this year’s team centers on achieving commendable performance within the competitive arena, the overarching goal is to provide undergraduate participants with a practical application of their engineering acumen toward a consequential real-world challenge. UAV Forge’s...

Cargo Plane 2023-2024

Spanning several years, UCI Cargo Plane is a well-renowned project at the University of California, Irvine. This project provides a great opportunity for undergraduate and graduate students to learn the fundamentals of aircraft design, as it brings together the foundations of aerospace engineering and combines it with hands-on manufacturing experience. In our specific case, members of the UCI Cargo Plane team will learn how to design a plane that carries metal weights. These skills will aid these members in future endeavors where they may design planes that could potentially carry more precious cargo. 

Given the formidable challenge by SAE, teams are expected to bring together unique perspectives in creating a one of a kind RC aircraft, capable of meeting all constraints. These constraints include power limiters and limited wingspan. Additionally, the Aero Design West Competition takes the common practice of RC aircraft competitions and raises the level of complexity, requiring...

Bike Builders

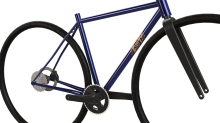
Many engineering students go through college without getting proper hands-on experience in the field. Therefore, we aim to give undergraduates the knowledge and experience to design, manufacture, and test their own bicycles. The club is applying knowledge from the classroom such as materials, mechanical stress, and CAD to a real-world industry application. Students who are currently participating often find direct correlations to the classroom when talking about manufacturing techniques. This is a unique opportunity for students to develop a holistic engineering approach by researching and implementing design and manufacturing processes.

For Winter 2024, project members will build miniature bicycle frames to build TIG welding and machining skills. The quarter will also be used to design and simulate their own frame design to be produced in Spring 2024.

Check out our first frame on our IG: https://instagram.com/ucibikebuilders?igshid=YzAwZjE1ZTI0Zg==


UAV FORGE

UAV Forge constitutes a multidisciplinary engineering design team with a specific focus on the comprehensive development cycle of autonomous aerial vehicles, encompassing design, manufacturing, programming, and rigorous testing. The paramount objective of this design endeavor is to adhere to the stipulated constraints, thereby enabling active participation in the SUAS 2023-2024 competition season.

The SUAS competition mandates that the UAV system possess autonomous flight capabilities, proficient object avoidance capabilities pertaining to both stationary and dynamic entities, and adeptness in object detection, localization, and classification. Furthermore, the system is required to execute an airdrop delivery mechanism, ensuring the precise delivery of a payload object to a designated GPS location without incurring any damage.

While the immediate focus of this year’s team centers on achieving commendable performance within the competitive arena, the overarching goal is to provide undergraduate participants with a practical application of their engineering acumen toward a consequential real-world challenge. UAV...

Human Powered Vehicle Competition at UCI

ASME hosts an endurance race that runs for 2.5 hours with many obstacles such as tight turns, uneven terrain, and inclines. HPVC at UCI will design and manufacture a recumbent, tadpole bike with a sufficient rollover protection system to keep the driver safe in case of an accident during the endurance race. The bike consists of 5 major systems: braking system, drive system, steering system, rollover protection system, and electrical system. The team has been split into three subteams: statics which consists of the bike frame, rollover protection system and seat; dynamics which consists of steering, braking, and driving; electrical which consists of the battery, electrical box and electric motor. Overall, the team aims to produce a bike that is ergonomic, safe, and easy to handle. 

While we are a senior design project, we also make sure to recruit underclassmen so they have hands-on experience and are prepared to succeed in their engineering careers. 

UCI CubeSat

UC Irvine CubeSat

The CubeSat team at UCI is a student-led undergraduate interdisciplinary research and design project with the goal of launching a 2U nanosatellite, AntSat 01, into orbit to test a UCI research payload. The satellite operates with five main engineering subsystems: Avionics, Communications, Structures, Power, and Systems. They all work to house STMS's (Spacecraft Thermal Management Systems) research payload within the 2U nanosatellite.

The research payload is a variable emissivity device (VED) that is developed by Spacecraft Thermal Management Systems (STMS). The payload will be tested as a thermal regulator, and our task is to evaluate its performance under varying levels of solar exposure and at different adjustable emissivity settings. We aim to determine if materials similar to the sample can serve as an inexpensive method for thermal management on future spacecraft.

BACKGROUND:
In recent years, the space sector has undergone a significant transformation with the emergence of...

Bluetooth-Enabled Weather Station


Description: This project aims to develop a Bluetooth-enabled weather station allowing users to access real-time, localized weather data via their smartphones. The weather station will be equipped with sensors to measure temperature, humidity, wind speed and direction, and barometric pressure for a complete weather profile of a given location. This project not only promotes user convenience but also advances our understanding of weather patterns and trends. Additionally, users will be able to make informed decisions regarding daily activities whether its planning outdoor events, assessing the need for climate control, or simply preparing for changing weather. Our goal is to provide a user-friendly, affordable, and accurate solution to homeowners, businesses, and educators alike.

Background: Our team consists of members with different interests and areas of expertise so we chose to pursue a project that would leverage each team member's unique skills and passions. 

Goals and objectives: By the end of the...

UAV FORGE

Project Description: 

UAV Forge is a multidisciplinary engineering design team focusing on designing, manufacturing, programming, and testing autonomous aerial vehicles. The design aims to fulfill the constraints that allow the team to participate in the AUVSI SUAS 2023 competition season.

The AUVSI competition requires that the system’s UAV have autonomous flight capabilities, the ability to perform object avoidance of stationary and dynamic objects, and the ability to do object detection, localization, and classification. The system must also perform an airdrop task wherein UAV Forge will manufacture an assembly that will interface the UAV with descent and autonomous ground vehicles.

AUVSI SUAS Competition: 

The ground vehicle, once landed, will autonomously drive to its set destination to complete payload delivery. Though the emphasis for this year’s team is to perform well in the competition setting, the primary objective is to ensure the undergraduate students participating in the project apply their engineering skills...

Beach Cleaning Robot


Background: 

The Beach Cleaning Robot Project is an undergraduate student lead project that aims to design and manufacture a trash-collecting robot to support coastal cleanup efforts. The goal for this team is to produce a remote-controlled, scalable prototype that can collect trash the size of plastic water bottles and snack bags/containers. 


Goal and Objectives:

• Finalize a list of requirements and constraints for our design 

• Create a concept that meets all requirements and attributes

• Finalize CAD of concept by 05/12/2023

• Complete a functional prototype by 06/9/2023


Midterm Presentation:

https://docs.google.com/presentation/d/1bhpozgORecW5Etl55LjynD7AwZ5MqIdC...

Final Report:

TBD

Prototype:

TBD


Team Contacts:

Sponsor/Advisor:

Human Powered Phone Charger

Background:

Smartphones have become increasingly more essential in the modern age since they allow us to connect with the outside world. As smartphones become more accessible comes the need for reliable and convenient methods of charging. Wall outlets and portable power banks are used to charge smartphones most of the time. However, they are not always accessible and reliable, especially in emergency situations and remote areas. Human-powered phone chargers provide an environmentally sustainable and portable solution for charging devices on-the-go. This project seeks to explore alternative solutions to charging that utilize human effort to ensure that charging is possible anywhere. The development of human-powered phone chargers is not new, as there are already existing designs and solutions on the market. However, there is a need to explore all avenues of mechanisms and human mechanical energy to improve its efficiency, portability, and affordability.

Goals and Objectives:

Our goal is to create...

Volleyball Machine Project: with Automated Collection System(Team Volleyballers)

VOLLEY BALLERS

An automated volleyball passing machine that will simulate the pass a libero might give, collect the setter's set into a net, then send through the passing machine again. The ideal passing component would be able to add backspin to the ball as one might see with a real pass. The person using the machine will then set the ball into a hoop with a rectangular net behind it to account for error. The volleyballs will be collected into a central location under the net and returned to the passing machine.

Solar Cooker

Welcome to our website, where we present our latest project aimed at designing, building, and testing a highly efficient solar cooker that uses only energy from the sun. Our objective is to create a cooker that works on sunny days, regardless of the angle of the sun, and that is inexpensive, compact, and lightweight. We believe that cooking with solar energy can be a sustainable and affordable solution in areas where fuel sources are limited, and that's why we focused on using easy-to-find materials and designing a cooker that is easy to assemble and disassemble. Our ultimate goal is to create a prototype that can cook something within a reasonable amount of time, making it a practical solution for people in need. We invite you to learn more about our project and follow our progress as we work towards creating a better future through sustainable cooking solutions.

Pages