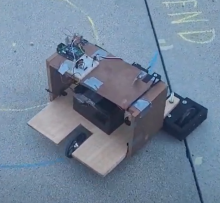
Bender ~ The Robot for Executing Physics Inspired Path Planner
Goal and Objectives
This open-ended project involves creating a robot, utilizing all steps of the engineering design process, to autonomously navigate around obstacles while following the shortest path. This project will be in conjunction with UCI graduate students developing a physics-inspired pathfinding algorithm, which we will utilize in our design in order to navigate an obstacle course. Our goal is to design and build a robot capable of: tracking a preplanned collision-free path in a 2D environment containing circular obstacles with a maximum error of 10% at any point, be able to pass through any two closely spaced obstacles and perform turn maneuvers without drifting off-course, when the path planner commands it to, and be self-contained and self-sufficient (no plug ins) and capable of running for at least 30 mins without recharge. As students in achieving the design project goal, we would have practiced all phases of the design process,...