All mechanical engineering students must undertake a capstone project in their senior year. The capstone projects are part of the 2-quarter Mechanical Engineering Design I & II course that is offered in Fall-Winter or in Winter-Spring. Students are guided by lecture material, mentors, and TAs while they work on their projects in teams of 3-6. The Department is always interested in collaborating with industry and/or community mentors who would like to have students work on an open-ended design project. An introduction to the mechanical engineering capstone projects program is available here. Please reach out to Professors Mark Walter (m.walter@uci.edu) or David Copp (dcopp@uci.edu) if you have any questions. 


Portable Water Filtration System (human power)

Over the world developing countries suffer from unsanitary water causing diseases such as cholera and dysentery. Our team Clean H20 2 GO is developing a portable hand pump water filtration system that is affordable, sustainable, and effective. For our design we are utilizing mechanical and carbon capture filters to eliminate most of the sediments and bacteria found in river water. Our system should be able to hold the minimum of 10 liters of clean drinking water to provide for a family of four. The mechansim for our design is a vaccum pump to efficiently filter the water and have an optimized flow rate to achieve full capacity in under 5 to 10 minutes. Other key components we look to optimize is low maintenance work and manufacturing cost to provide easy use for these communitites.
Electric Powered Water Filtration

The World Health Organization published that more than 884 million people did not have access to safe drinking water in 2017. Unsanitary water can cause different diseases like cholera, dysentery, and polio. The goal of this project is to design and build an affordable, portable, and sustainable water filtration system that can provide clean drinking water for one day for a family of four in developing countries. This team will design a system that uses electric power to operate a pump or similar device to move water from the source to the designed filtration system.

Autonomous Target Robot Project


  • Background 
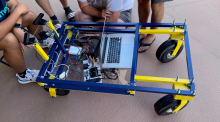
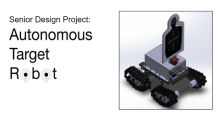
    • The autonomous target robot project is a project sponsored by the US Navy that is seeking to create a vehicle that navigates autonomously and is capable of acting as a mobile target on a shooting range.
  • Goal and Objectives  
    • Design the structure for an autonomous vehicle
    • Write a program that directs the car to pre-designated GPS coordinates and presents a target oriented towards the shooter
    • Incorporate sensors that detect when the target has been shot, allow autonomous navigation, and wireless communication
    • Manufacture the robot and assemble electronics
  • More Information
    • Sponsor/Advisor
    • Engineering challenge we are working on:
      • The Arduino systems that the robot functions off of can prove difficult to work if you are expecting a high amount of precision and/or lack of corrupted data
  • ...

Autonomous Underwater Vehicle

The Autonomous Underwater vehicle project is created by a student-led group of Mechanical Engineering students working with Professor Camilo Velez to study and manufacture a swarm of small scale robots that can swim underwater. Our inspiration for this project stems from the idea that nano robots can work together to detect, isolate and remove a single cell in the human body. In an effort to work towards this idea, our team is set to construct a number of small-scale robots that can autonomously navigate 3-Dimensionally in a swimming pool to detect and attach magnetically to a specified item.

UCI Intelligent Ground Vehicle W22

Background

Students that are a part of the UC Irvine Intelligent Ground Vehicle Team will design and test an autonomous ground vehicle that is able to navigate through an obstacle course. The technologies used in IGV encompass a wide range of applications in engineering including military mobility, intelligent transport systems, and manufacturing. 

Goals and Objectives 

The goal for students in IGV is to implement skills gained in classes while designing the vehicle and developing a method to allow it to navigate through the obstacle course. This includes usage of Finite State Machines, Ultrasonic and GPS Sensors, and microcontrollers. 

Currently, the project is in the optimization stage. The chassis has been built and the obstacle detection code, GPS, and navigation systems are nearly complete. The next steps are to reconstruct the chassis using a more flexible material as the plexiglass was very unwieldy. Furthermore, we plan to optimize the lane detection...

FUSION Engineering Project 2021-22

Like many professional organizations at UCI, FUSION takes pride in providing experience and opportunities to eager students. We believe in Social support, Professionalism, Academia, Culture, and Engineering as pillars for our club. Each of these pillars are deeply embedded in our annual engineering projects. Since the beginning of this club, iterations of the club projects gained recognition for providing valuable experience and lessons for the participating students. This year, FUSION presents the 2021-2022 Engineering Project: Hungry Hungry Hippos.

Despite the nostalgic name, this project demands several disciplines of engineering, organization, and commuincation from each of the participating students. Three teams must create a robot that collects gold coins within a provided field both autonomously and through manual control. Not only will these teams build towards item recognition and retrieval, but must also plan against other competing teams as well as FUSION's own administrative team known as the Goldkeepers. With little design restrictions and a strong budget, this year-long project will test the strategies...

RF-Controlled Unmanned Ground Vehicle

The RF-controlled Unmanned Ground Vehicle (UGV) is designed to perform jobs without a human operator onboard. Each RF-controlled UGV is designed differently to perform different tasks. An RF-controlled UGV would be perfect for the inspection of steel structures because the job could be very dangerous to human operators, and UGVs can be used for both civilians and military projects. A UGV makes it possible to perform inspections under realistic time constraints, where not only human errors will be avoided but also in locations human being would normally be unable to go. This process of steel inspection is multipurpose, meaning the UGV design will be able to accomplish multiple jobs. Furthermore, the advantages of the UGV is that it reduces injuries and fatalities in all parts of the steel inspection process.

Morf NX

Morf NX

Project Background:

For the winter and spring quarters of 2022, Siemens and Morf 3D have partnered up with the University of California, Irvine to teach senior-level Mechanical Engineering students using their CAD software, NX, emphasizing additive manufacturing in the aerospace industry. To get the UCI team familiarized with the NX software and the concept of additive manufacturing in the aerospace industry, Siemens and Morf 3D engineers will work alongside the UCI team. This project will serve as a guide to learn how additive manufacturing will be the future of the aerospace industry and the manufacturing industry because of the digitalization of engineering design projects in the industrial sectors. In this quarter, the UCI team will learn about engineering in the industry, applying applicable engineering design processes, modifying parts, making the correct design and manufacturing decisions, and ultimately designing effective support structures for the parts provided by Siemens and Morf 3D.

UCI IGV (Intelligent Ground Vehicle)

As technology advances, being autonomous has become a trending focus. Imagine cars can drive by themselves, foods can be delivered without human interaction, and rescuing jobs can be handled by autonomous robots. Aiming to achieve these wonderful outcomes, UCI IGV (Intelligent Ground Vehicle) team is formatted under the supervision of the UCI Mechanical Engineering department. Our goals are to design and fabricate an autonomous ground vehicle that can detect and avoid obstacles. The team is divided into three subteams, control, electrical, and mechanical. Each team has unique tasks and works closely with the others. The mechanical team mostly focuses on the mechanical side of the project. We aim to design a stable steering system that is capable of achieving a wide range of turning angles and a propulsion system that provides sufficient power that drives the vehicle forward at a reasonable speed. 

Steerable Mechanical Walking Robot

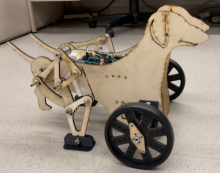
The steerable mechanical walking robot is a project that uses a motor-driven Jansen leg mechanism to move, while also using a separate servo motor to steer the robot through a bell crank mechanism. The robot is wirelessly controlled via infrared, having buttons on the IR remote command the robot to turn left or right, go forwards or backward, and also to stop.

An Arduino UNO facilitates the electronics control of the robot, processing IR signal from an IR receiver, which promptly translates it into an action. The Arduino is powered by a rechargeable lithium-ion battery.

A motion study was used with a CAD model to analyze the motion of the physical prototype before building the robot. The final prototype uses a Jansen-style leg mechanism, which uses 11 linkages to mimic the walking motion of a leg. 

UAV Forge Noise Reduction

Background 

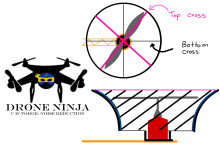
Drones are rapidly becoming a part of modern day life. Their ease of use and relatively low price has made drones more accessible to the public than ever. Similarly, companies such as Amazon are researching and developing drone based delivery systems to be used within cities. However, noise nuisances are disrupting and even unhealthy with prolonged exposure. Therefore, it is necessary to find a way to reduce the noise level of the drone. Under this background, our group would like to design an attachment that would reduce the noise of a drone.

Goal and Objective

The goal of this project is to reduce the overall noise of a drone by 5-15 dB. The attachment needs to have reasonable price. It needs to be light weight and shouId not negatively influence the aerodynamics of the drone. The attachment is also required to be easily mountable and avoid unnecessary vibration. In...

Recreate Energy

Recreate Energy : Energy for a Brighter Future

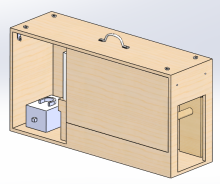
The goal of this project is to turn microalgae into crude oil for commercial use. The students must design effective growing systems - from physical tanks, to electronics, to regulating the environment - to turn the algae into fuel that results in cheap, clean, compatible fuels. Recreate Energy has previously tested the optimal algal growing conditions to build the reactor around and has already signed with a company to deliver a commercial ready bio-reactor with web management platform.  Recreate Energy is currently developing modular bioreactors, compared to the previous exclusively on open-air systems or closed-controlled systems, to lower costs and include the best of both systems when it comes to algae cultivation for biofuels. The project is separated into 3 sub teams that deal with specific design considerations: Temperature Control, Electro-Flocculation, and Electronic Box. 

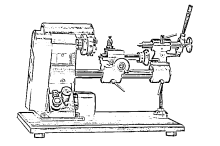
RF Controlled Miniature Lathe: Spin Class

The RF Controlled Miniature Lathe project surrounds the conceptualization, design, and construction of a tabletop lathe that can be controlled and used to alter the inserted material without direct interaction with the machine. The miniature lathe's remote control capabilities will be supported by a radiofrequency controller, with joysticks that will allow for four directional movement: right, left, forward, and backward. In instituting a remote control option, users will be able to maintain a safe distance from the machine, even standing behind a glass shield, and still be able to chisel and sand the piece in question. As opposed to machining metal or solid wood cylindrical pieces, the mini lathe will process high-density closed cell foam. Fabrication of the lathe itself will combine 3D printed parts with manufactured wood components. 

Fastener-less Flange

UCI School of Engineering Relativity Space Logo

Relativity Space has partnered with UCI to create a senior design project set to redesign the flange. With bolted flanges currently being the primary method of reversable attachment of two pipes it’s simple design and out of date manufacturing process has left much room for improvement. We have set forth to design, test and manufacture a prototype flange that is 3D printed, light weight, and maintains ASME flange standards.

UCI CubeSat

UCI CubeSat is a student design team working on the design and construction of UCI's very first CubeSat satellite. Our mission is to deliver two research payloads to low earth orbit.

Autonomous Systems: Unmanned Floating Vehicle

Background

The use of unmanned buoys for data collection is not a new concept as government offices such as NOAA utilize them for the collection of weather and oceanic data. The reliability of such systems has been a key focus for development. As of 2020, 10% of NOAA’s buoys have become inoperable. These reliability challenges necessitate the need for an external method of data collection as a portion of the buoys labeled inoperable may have simply experienced a malfunction in their communication systems. As this is the case for simple peacetime equipment, the need for a physical data transfer system is further necessitated by the complexity of wartime systems. An unmanned vessel that is capable of navigating to a buoy, establishing a physical connection, and downloading data would mediate these losses in buoy performance. Furthermore, such buoys could be designed without communication systems which would allow for lower profile designs...

UCI Solar Car Project

Goal and Objectives

This year, the team is dedicated towards continuing too manufacture a car that will be powered by battery in order to compete our first vehicle version. Once the car is manufactured and tested, we will be able to enhance certain features which will allow us to compete in American Solar Challenge (ASC), a race in which teams are expected to create a solar-powered car that can travel along predetermined routes such as Route 66 and the cross-country passage from Texas to Canada. Through this process, Solar Car not only strives to produce an efficient machine for a succesful run at the ASC, but also hopes to expand the innovation and utilization of renewable energy sources. 

As the Fall quarter progresses, students have continuously worked in lab to design, test and manufacture mechaniccal and eelectrical components needed for the developmnt of our vehicle!

Contacts:

Project Manager: Hallie Park, parkhm2@uci.edu

Advisor

Penghui Cao, caoph@uci.edu

HyperXite

Background

Established in 2015, HyperXite is a team of undergraduate students endeavoring to build a Hyperloop pod.

HyperXite has competed in the past four SpaceX Hyperloop Pod Competitions. In the SpaceX Competition I, HyperXite was one of the semifinalists and placed fifth for their overall design worldwide. Additionally, the HyperXite pod was one of the only air-levitated pods to be tested within the Hyperloop itself during Competition II and placed in the Top 6. In the past two competitions, HyperXite was one of the top 22 finalists to attend the competition in Hawthorne, CA. 

This year, HyperXite will be attending the European Hyperloop Week, a Hyperloop competition established in 2020, and will build a small-scale pod to compete in the Netherlands during the summer of 2022.

Goal

HyperXite’s goal is to research, design, build and validate a scalable self-propelled pod to demonstrate the feasibility of Hyperloop design concepts at a high pace of innovation.

Objectives...

Long Range Drone

The mission of the Long Range Drone Senior Project is to create a lightweight drone that can fly for thirty minutes or longer using stored electrical power by the end of the winter quarter in 2022. The drone will carry a camera for navigational purposes. The drone will be designed to accommodate a hydrogen fuel cell by spring quarter of 2022.


This project is a small team of five people dedicated to learning the engineering design process and getting hands-on experience with mechanical and electrical components of drone design. There are currently no competitions in which the team participates.

Anteater Formula Racing (FSAE Internal Combustion Engine) 2021-22

Background:

Each year, Anteater Formula Racing designs, manufactures, tests, and competes with an open-wheel car modeled after Formula 1 racecars. Formula SAE (Society of Automotive Engineers) is an international organization that puts on competitions worldwide every year. There are dynamic components that involve racing the car itself, and static components that revolve around testing students knowledge of the engineering design process and business tactics. This year, the team will be working on the newest iteration of the car, named "Peter the Pavement Eater" or, PPE for short.

The team of 45 students participate in the design, manufacturing and testing phases to gain the engineering skills needed for industry in a highly-technical, fast-paced and competitive environment. The team collectively spends over 15,000 hours each year developing the car and its subsystems while balancing their engineering coursework.  

Engineering students earn jobs in several industries, including automotive, aerospace, electrical, software and more, because of the hands-on training and...

UC Irvine Solar Airplane

The objective of UCI Solar Airplane Project is to design and manufacture a UAV that can assist with planning rescue missions and evacuation operations during natural disasters. The UAV will have its flight duration extended, at least by 30 minutes beyond battery-only duration, by installing solar panels. The imagery the proposed UAV will be able to collect can be used for the missions during natural disasters. A low-cost drone is more accessible by organization while still performing small imaging collection tasks. The proposed UAV will be able to fly at low heights to achieve a very low ground sample distance. The drone can aid with disaster relief efforts where accessibility is difficult for humans or visibility is limited.

UCI Design Build Fly

Summary

The UCI DBF team plans to compete in the annual, nationwide competitionThe American Institute of Aeronautics and Astronautics (AIAA) Design, Build, Fly (DBF) .The UCI team is divided into different divisions/subteams to work on specific parts for the aircraft. This page is for the payload subteam. We are responsible for the design of the fuselage and the drop mechanism of the team's aircraft, mainly focusing on Missions 2 & 3 of the competition. Missions will include deployment of the aircraft, staging of vaccination syringes, and delivery of vaccine vial packages with integrated 25G shock sensors which should not be triggered.. This team consists of students of all year levels working alongside each other to accomplish a common task and goal.

DBF 189 Capstone

This is the payload subteam of the AIAA Design Build Fly Team at UCI. Our subteam is in charge of designing the fuselage to hold vaccine syringes and the drop mechanism to release the syringes. Our goal is to release syringes carefully and quickly to deliver as many syringes as possible without compromising the integrity.

Our team’s goal is to design and build a bomber style aircraft that will instead be used to release vaccine syringes. The payload subteam will be in charge of designing the fuselage to hold syringes and a drop mechanism to individually release syringes. We will strive to release the vaccine syringes as quickly and as safely as possible.

Small Scale Wind Turbine

Maintaining lines of communication is vital in emergency situations. One major concern for those living in rural areas is being cut off from the electrical grid during natural disasters. The small-scale wind turbine project aims to design a scaled down wind turbine sized for a single household's personal use, in case of an emergency. The wind turbine should be capable of powering household devices needed in emergency situations, such as radios, lightbulbs and cellphones.This project encompasses the designing,  optimization and a fully developed manufacturing plan for the assembly of the wind turbine, as well as each of its constituent components.

UCI Intelligent Ground Vehicle 2021

Background

Students that are a part of the UC Irvine Intelligent Ground Vehicle Team will design and test an autonomous ground vehicle that is able to navigate through an obstacle course. The technologies used in IGV encompass a wide range of applications in engineering including military mobility, intelligent transport systems, and manufacturing. 

Goals and Objectives 

The goal for students in IGV is to implement skills gained in classes while designing the vehicle and developing a method to allow it to navigate through the obstacle course. This includes usage of Finite State Machines, Ultrasonic and GPS Sensors, and microcontrollers. 

Currently, the project is in the optimization stage. The chassis has been built and the obstacle detection code, GPS, and navigation systems are nearly complete. The next steps are to reconstruct the chassis using a more flexible material as the plexiglass was very unwieldy. Furthermore, we plan to optimize the lane detection...

UCI CanSat / AntSat

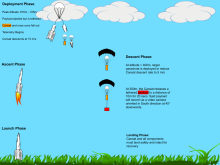
The CanSat competition is a design-build-fly competition that provides teams with an opportunity to experience the design life-cycle of an aerospace system. The CanSat competition is designed to reflect a typical aerospace program on a small scale and includes all aspects of an aerospace program from the preliminary design review to post mission review. The mission and its requirements are designed to reflect various aspects of real world missions including telemetry requirements, communications, and autonomous operations. Each team is scored throughout the competition on real-world deliverables such as schedules, design review presentations, and demonstration flights.

Design Build Fly

As indicated by the title “Design, Build, Fly”, this project involves the design of an aircraft for the purpose of completing three air missions and one ground mission, building components of the aircraft that are not commercially available, and testing and flying the aircraft. The design of the aircraft is optimized solely to complete the missions. The missions are as follows: For mission 1 (deployment flight), the aircraft must complete 3 laps within a 5 minute flight window without a payload and complete a successful landing; For mission 2 (Staging Flight), the aircraft must complete 3 laps within a 5 minute flight window with a payload of at least 10 syringes; For mission 3 (Vaccine Delivery Flight), the aircraft has 10 minutes to  complete as many ‘vaccine package’ deployments as possible; Finally, ground mission is a timed mission with the aircraft in the flight configuration in the “mission box” with Mission 2 and 3 payloads. The assembly crew must demonstrate the functionality of the aircraft by deploying all payloads. The design of the aircraft will focus on the requirements of the third mission where the aircraft must be able to complete a flight course within a time window while carrying a payload and making several takeoffs and landings. The wings, fuselage, empennage, will be drawn and built by the team. Components such as the battery, propellers, motors, wheels will be carefully selected to meet the aircraft performance requirements. The team is divided into sub teams that focus on aircraft performance, propulsion, CAD, payload and the like. 

Anteater Baja Racing SAE

Background:

The UCI Anteater Baja Racing SAE team competes yearly in the Baja SAE West Collegiate Design Competition hosted by the Society of Automotive Engineers. Each year the team develops a brand-new single-seat off-road vehicle for the competition based on research into the dynamics of off-road vehicles and a critical analysis of the previous year’s car. The yearly competition hosts 100 collegiate teams from across the world and consists of a series of static and dynamic events culminating in the 4-hour, 100 car wheel-to-wheel endurance event. 

Goal and Objectives:

The objective of the 2021-2022 UCI Baja SAE team is to develop a reliable, competitive single-seat off road vehicle to place among the top 20 teams in the upcoming 2022 Baja SAE West competition. In order to accomplish this, the 2022 competition vehicle, named Vandal II, must be the lightest, fastest, best performing, and most reliable vehicle that the team...

Pages